

 Contact Us


 Home /
Robotic Weld Inspection: Visual Checks, NDT, and What Camera Images Cannot Prove
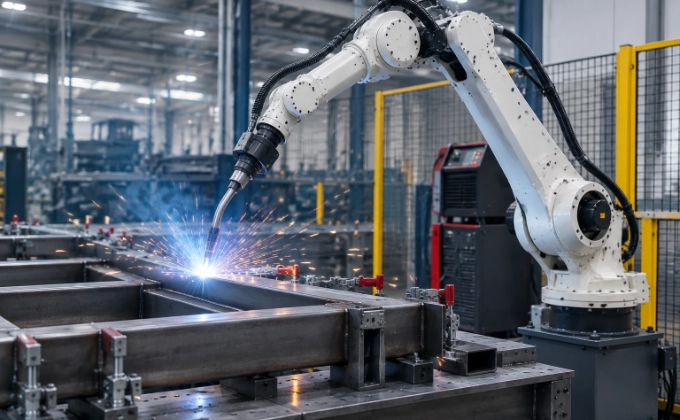
Robotic Weld Inspection: Visual Checks, NDT, and What Camera Images Cannot Prove
Oct 14, 2026

Autonomous Trailer Loading: When Warehouse AMR Capability Is Not Enough
Oct 14, 2026

Robot Demonstration Data for Research: Synchronization, Labels, Resets, and Reproducibility
Oct 14, 2026

Robot Path Blending vs Exact Stops: Corners, Process Quality, and Cycle-Time Trade-Offs
Oct 13, 2026
A camera mounted next to a welding torch can watch every pass, log every arc, and stream a clean image of the finished bead. It is easy to treat that stream as proof that the weld is sound. It is not. A surface image shows the surface. It says almost nothing about what happened below it, and the gap between "the picture looks good" and "the joint will carry its load" is where most weld quality disputes start.
The fix is not to buy a better camera. It is to decide, before anyone quotes a robot cell, what evidence the weld actually needs, and then to check whether each method can produce that evidence. This article walks through that decision in the order a quality engineer should make it: define the defects, separate monitoring from inspection, understand what visual checks can and cannot show, match NDT to the joint, plan sampling and traceability, and assemble the evidence chain that a buyer, an inspector, and a customer can all read the same way.
Specify the Defects and Acceptance Criteria
Start with the part, not the sensor. What failure modes matter for this joint? A pressure boundary cares about lack of fusion and incomplete penetration. A dynamically loaded bracket cares about toe cracks and undercut. A cosmetic panel cares about spatter and bead profile. These are different defects, and they demand different evidence.
The acceptance criteria come from the product requirement and the governing code, not from whatever the camera happens to detect well. For structural steel, AWS D1.1/D1.1M covers design, qualification, fabrication and inspection requirements. Use the edition and acceptance criteria specified for the contract. A passing visual inspection against the specified fabrication acceptance criteria does not, by itself, demonstrate that the connection meets the project's design-load requirements. Keep the welding inspection record and the engineering verification as separate evidence.
Write the criteria down before the cell is specified. A useful first pass is a simple table: defect type, where it can occur, how it will be detected, what evidence proves it, and who signs off. If the table has a row where the only evidence is "robot camera image," that row is already a problem.
Separate Process Monitoring from Inspection
These two words get used interchangeably, and that is the root of most confusion.
Process monitoring is what happens during the weld: arc current and voltage, wire feed speed, travel speed, gas flow, and sometimes a camera watching the pool or the seam. Its job is to keep the process inside its window and to flag a drift while the part is still hot. It is a control signal.
Inspection is what happens to the finished joint: it asks whether this specific weld meets the acceptance criteria. It produces a verdict, not a trend.
A seam-tracking camera that keeps the torch on the joint is doing process monitoring. It is not inspecting the weld. A vision system that measures bead width and detects surface porosity is doing surface inspection. It is not evaluating fusion. Confusing the two leads to the classic error of treating a monitoring dashboard as a quality record.
The practical rule: if a signal cannot, by itself, produce a pass/fail on a named defect against a named criterion, it belongs on the monitoring side of the line, and it cannot be the sole basis for releasing a part.
Understand Visual Inspection Limits
Visual inspection is real inspection, and it is often the first line of defense. It reliably finds surface-breaking defects: cracks visible at the toe, surface porosity, undercut, overlap, excessive spatter, arc strikes, and gross dimensional problems like bead misalignment. For many joints, a trained eye with good lighting and the right tools catches what matters.
What it cannot do is see inside. A clean, uniform bead can sit on top of lack of fusion, incomplete penetration, or internal porosity. Those are volumetric or subsurface conditions, and no amount of surface resolution resolves them, because the information is not on the surface to begin with. Photographing a good-looking cap does not prove the root passed.
There is also a subtler limit: visual inspection is a skill, not a camera. ISO 9712:2021 covers qualification and certification for specified industrial NDT methods, including visual testing, but expressly excludes direct unaided visual tests and visual tests performed as part of another NDT method. Apply the qualification scheme that the actual contract and inspection procedure require. A robot that captures an image is not a qualified visual inspector, and an image is not a visual inspection result unless someone competent interprets it against the criteria.
Match NDT or Destructive Tests to the Joint
When the acceptance criteria call for evidence that visual checks cannot provide, the answer is nondestructive testing, chosen to suit the joint and the defect of concern. The method follows the defect, not the other way around.
Surface and near-surface: penetrant testing finds surface-breaking discontinuities on nonporous materials; magnetic particle testing finds surface and slightly subsurface discontinuities in ferromagnetic materials. Both are surface methods and do not see deep internal flaws.
Volumetric: radiographic testing images internal density changes, and ultrasonic testing detects and locates internal discontinuities. Ultrasonic methods have grown well beyond the basic manual scan. Phased-array ultrasonic testing uses multi-element probes and electronic beam steering to detect and characterize discontinuities under a suitable procedure. Time-of-flight diffraction can contribute detection and sizing evidence in qualified applications. Neither method has a universal advantage over radiography or manual UT for every defect orientation and joint geometry. A worked example of this is in the CCS guidance for thick-plate hull welds, which combines TOFD and PAUT and specifies the personnel and system requirements for the combination.
The critical caveat: method suitability and personnel qualification are decisions for a qualified professional, not for a supplier's brochure and not for this article. What a buyer can do is require that the proposed method be justified against the specific defect type and joint geometry, and that the people performing it hold recognized certification. ISO 9712 and the employer-based SNT-TC-1A scheme both exist; the buyer should know which one governs the contract, because they are not the same system.
Plan Sampling, Traceability, and Rework
Inspection that is not tied to a specific weld on a specific part is not inspection, it is a demonstration.
Sampling has to be defined up front: which welds are inspected, at what rate, by which method, and what happens when a sample fails. For critical joints the answer may be 100 percent volumetric inspection. For others, statistical sampling is defensible, but only if the sampling plan is written and the failure response is defined.
Traceability links each inspection result back to the actual weld. That means the weld has an identity, the inspection record carries that identity, and the two can be reconciled later. Process records (parameters, operator, consumable lot) should attach to the same identity. Without this, a beautiful inspection report proves that a weld passed, not that this weld passed.
Rework deserves its own line in the plan. A repaired weld is not the original weld. It has a new thermal history, new residual stress, and often a new defect risk. The plan should state what happens after a repair: whether the weld is re-inspected, by which method, and against which criteria. "Repair and move on" is not a plan.
Build the Evidence Chain
The output of all this is a matrix that anyone in the chain can read. One row per weld type, with columns for: the process record (what was welded, with what parameters), the inspection method (visual, PT, MT, RT, UT, PAUT, TOFD), the acceptance criterion (which code clause, which limit), the responsible party (who performs it, who holds the qualification), and the result (with the traceable identity).
Build that matrix and the camera question answers itself. The camera takes its place as a monitoring tool and, where it genuinely detects a surface defect, as one input to surface inspection. It stops being asked to prove things it never could. The buyer who builds the evidence chain before specifying the cell avoids the most expensive mistake in robotic welding: paying for a system that documents the wrong thing beautifully.
Turn Weld Images into an Evidence Request
If you are evaluating a robotic welding cell, send the joint type, acceptance code and any available inspection-plan or sensor-document excerpts. AIsirRobot can help coordinate a model-specific manufacturer-document request and identify which inspection records, revisions and sign-off responsibilities still need clarification. Qualified weld engineers and NDT personnel decide the acceptance method. Organize the weld-evidence document gaps.
Share on Social:


- PREV: Autonomous Trailer Loading: When Warehouse AMR Capability Is Not Enough
- NEXT: Not NEXT
Contact Us
In This Article
Robotic Weld Inspection: Visual Checks, NDT, and What Camera Images Cannot Prove
Oct 14, 2026
Autonomous Trailer Loading: When Warehouse AMR Capability Is Not Enough
Oct 14, 2026
Robot Demonstration Data for Research: Synchronization, Labels, Resets, and Reproducibility
Oct 14, 2026
Robot Path Blending vs Exact Stops: Corners, Process Quality, and Cycle-Time Trade-Offs
Oct 13, 2026